Robotics · Mechanisms · Humanoid Hardware

Seungbin You 유승빈

Researcher, Center for Humanoid Research
Korea Institute of Science and Technology (KIST)

I design robotic actuators and mechanisms, from transmissions to humanoid systems.

Portrait of Seungbin You

Seungbin You is a Researcher at KIST's Center for Humanoid Research. His work focuses on robotic actuation, mechanism design, and humanoid hardware.

His research combines mechanical design, modeling, and experiments across transmissions, joints, robotic hands, and integrated systems.

Research direction

Task-matched mechanisms and actuators balancing precision, backdrivability, load capacity, and robustness.

Representative research

Plate Harmonic Reducer

The Plate Harmonic Reducer reconfigures strain-wave gearing around a thin plate flex spline, enabling a compact axial form for robotic joints. The work spans mechanism design, analytical modeling, and experimental characterization of efficiency, stiffness, accuracy, and load transmission.
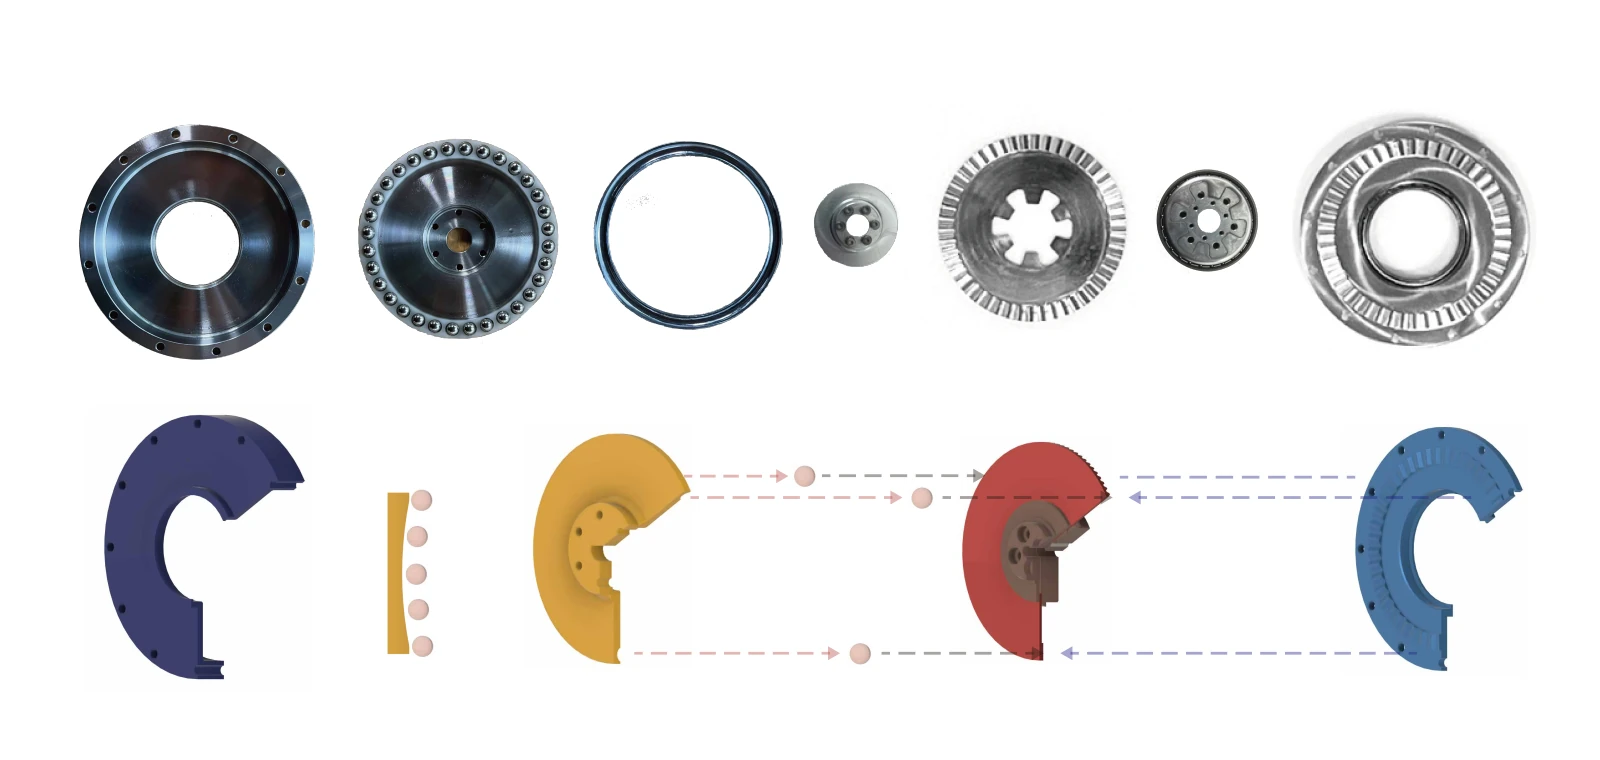
Prototype components and exploded structure of the Plate Harmonic Reducer
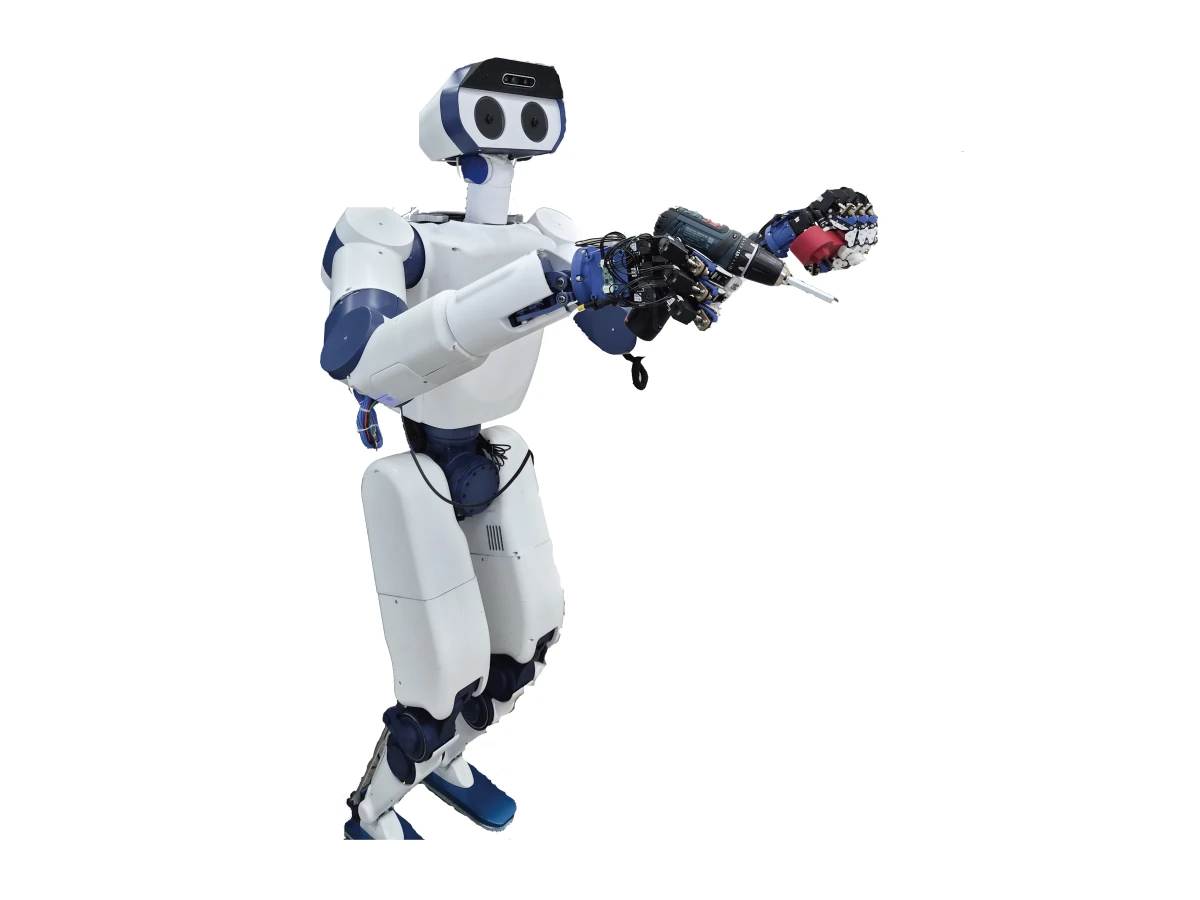
Human-scale humanoid platform performing a tool-use task

Humanoid platform design

Platform architecture, joint configuration, actuator selection, and mechanical integration for a human-scale humanoid.

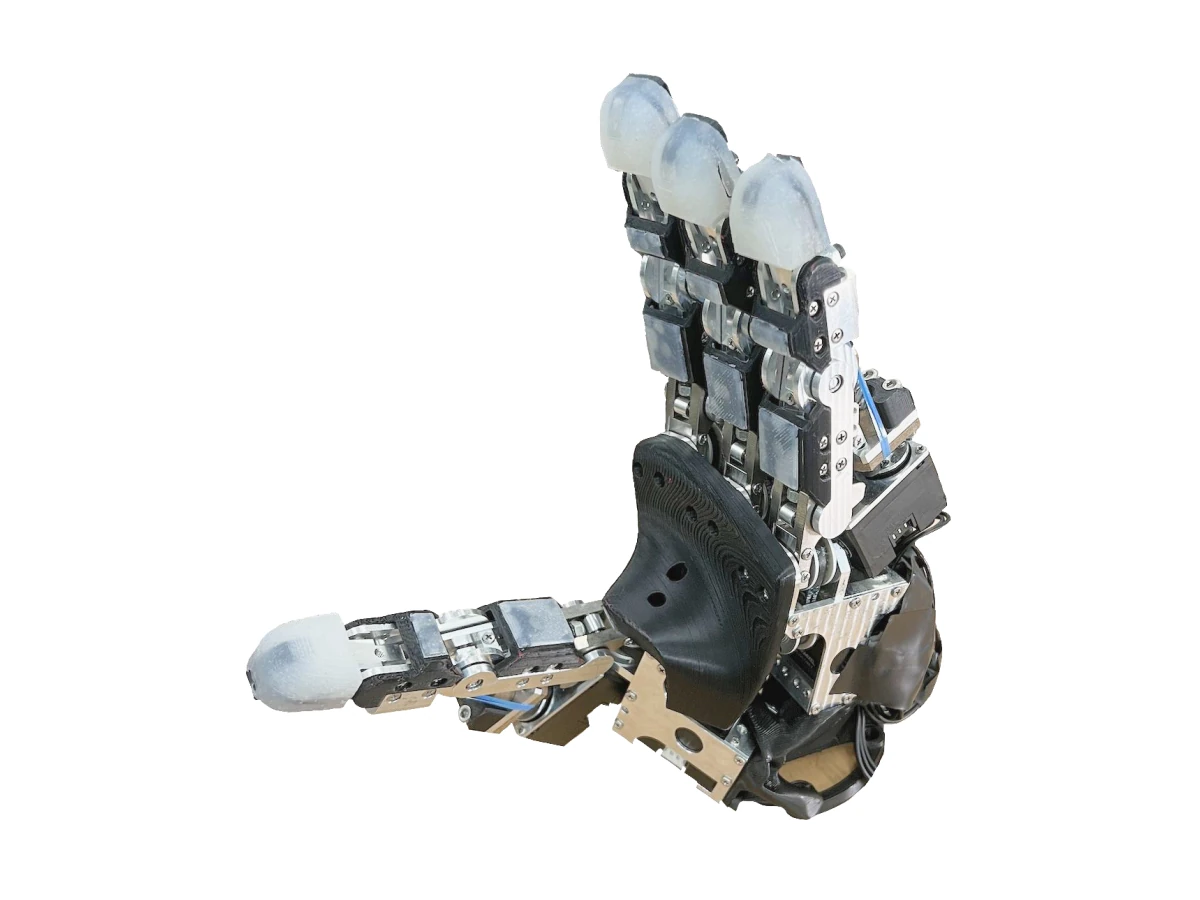
Four-finger robotic hand prototype with compact linkage mechanisms

Robotic hand mechanisms

Research guidance on compact joint and finger mechanisms for modular robotic hands.

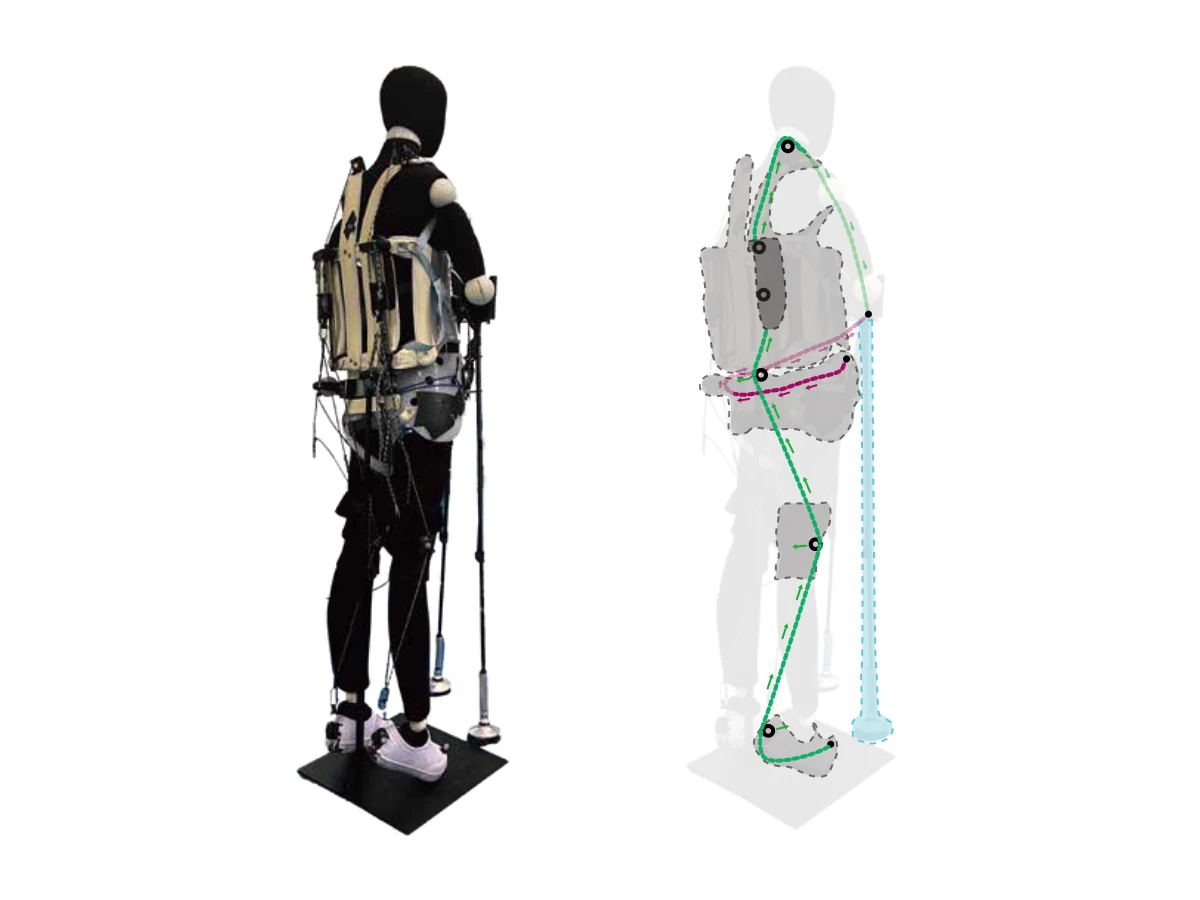
Wearable walking prototype and its tendon-routing mechanism

Assistive walking mechanisms

Design and experimental evaluation of a tendon-driven wearable prototype for walking assistance.

Selected journal and conference papers. Complete list on Google Scholar ↗

  1. 2026Journal

    SNU-Avatar Haptic Arm: A Hybrid QDD/DD Operator Interface for Teleoperation

    Eunho Sung, Seungbin You, Jaeyong Shin, Suhan Park, Sungmoon Hur, Jaehun Kim, Seunghwan Byun, Chaiyong Mun, Haeseong Lee, Dongjun Kim, and Jaeheung Park

    IEEE Access, vol. 14, pp. 57409–57426

    Paper ↗
  2. 2026Journal

    Mechanical Analysis of Plate Harmonic Reducer Considering Deformation of Thin-Plate Flex Spline

    Seungbin You, Eunho Sung, Dongjun Kim, Jaehun Kim, and Jaeheung Park

    International Journal of Precision Engineering and Manufacturing

    Paper ↗
  3. 2025Journal

    Semidirect Drive Based on Tri-Contacted Plate Harmonic Reducer

    Seungbin You, Eunho Sung, Dongjun Kim, Juhyun Kim, and Jaeheung Park

    IEEE/ASME Transactions on Mechatronics

    Paper ↗
  4. 2024Conference

    SNU-Avatar Haptic Glove: Novel Modularized Haptic Glove via Trigonometric Series Elastic Actuators

    Eunho Sung, Seungbin You, Seongkyeong Moon, Juhyun Kim, and Jaeheung Park

    IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 3573–3580

    Paper ↗
  5. 2022Conference

    Plate Harmonic Reducer with a Profiled Groove Wave Generator

    Seungbin You, Jaesug Jung, Eunho Sung, and Jaeheung Park

    IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 1900–1907

    Paper ↗

Education

2026

Ph.D. in Intelligence and Information Convergence

Seoul National University
Advisor: Prof. Jaeheung Park
Dissertation: Modeling, Design, and Performance Analysis of Plate Harmonic Reducer

2021

M.S. in Intelligence and Information Convergence

Seoul National University

2018

B.S. in Mechanical Engineering

Yonsei University

Professional experience

Feb 2026–present

Korea Institute of Science and Technology (KIST)

Researcher · Center for Humanoid Research

Apr 2025–Jan 2026

BlueRobin

Humanoid Project Lead · Mechanical Design

May 2018–Sep 2019

Schaeffler Korea

Application Engineer

Korea Institute of Science and Technology
Center for Humanoid Research
Seoul, Republic of Korea